 Xingxin on Bug
Pico 4
My next project will use the Franka DUO as the embodiment. Because of this, my previous single Franka Research 3 arm teleoperation setup (using XBox gamepad and Gello) needs an upgrade. Since this is a bimanual setup, I am exploring teleoperation methods that are much closer to how humanoid robots operate.
We chose PICO 4 as our teleoperation device because it has been used successfully in several solid papers including
- 📄SONIC: Supersizing Motion Tracking for Natural Humanoid Whole-Body Control
- 📄TWIST2: Scalable, Portable, and Holistic Humanoid Data Collection System
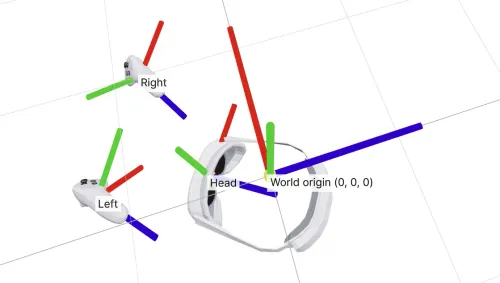
The latest progress is that I can now successfully extract the 6D Pose (rigid transformation) of the headset and the left and right controllers.
Pick Up Reinforcement Learning
Before struggling with the ICRA deadline, I kept a habit of studying reinforcement learning after work, following John Schulman’s advice. I had to pause for a few weeks due to the sheer volume of experiments I needed to run, but now I am back at it.
The human brain is a very funny thing. Just a few weeks off can completely wipe away my knowledge on value iteration and the Bellman backup! As I recall from Barbara Oakley’s A Mind for Numbers, forgetting like this simply reveals that my neural pathways for these reinforcement learning concepts are not solid enough yet.
It is a great reminder that I need to double down on active retrieval practice and spaced repetition, rather than just passively re-reading the material. Still a long way to go!