 Xingxin on Bug
Tuning the Gripper
One major accomplishment for me this week was disassembling a Robotiq Hand-E gripper from a UR robot, reassembling it onto the Franka, and configuring it completely from scratch using the Robotiq ROS2 driver. It forced me to dive into hardware, which is a completely unfamiliar territory for me!
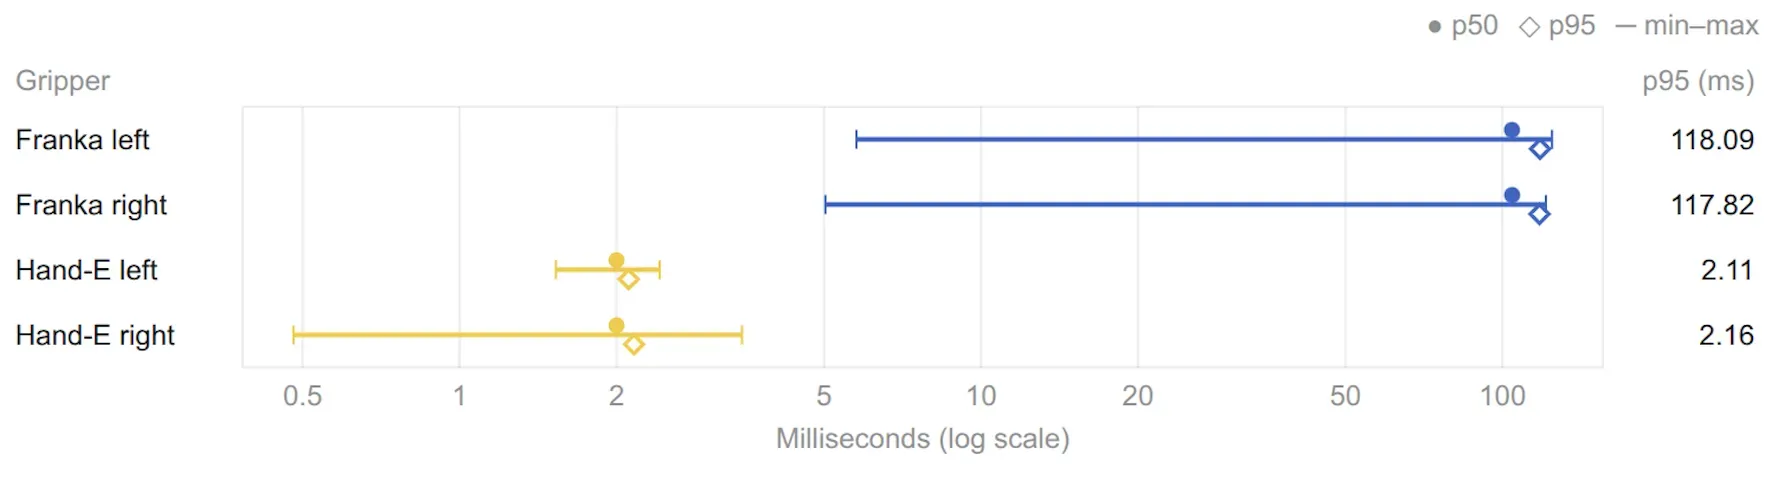
In my test, the Franka Hand averaged about 15 state updates per second, but the updates arrived at uneven intervals. A steady 15 Hz stream should deliver an update every 67 ms, but I measured a median (p50) gap of about 104 ms and a p95 gap of about 118 ms on both sides. In contrast, the Robotiq Hand‑E status updates arrived much more regularly, with a median gap of 2.0 ms and a p95 of 2.11-2.16 ms.
Policy Evaluation
According to my study plan, I only have two sections left before I can officially move into rigorous learning of PPO and SAC. I am currently building my stamina for policy optimization and I finished Monte Carlo Policy Evaluation in Continuous RL this week.
Intermediate Windsurfing
I completed an Intermediate Windsurfing Training course this weekend! This was my first time using the Techno 293, the same board design chosen for the Youth Olympic Games! As you can imagine, controlling this board is a whole different level of challenge :-)
Sadly, the wind conditions stayed below a Level 3 on the Beaufort scale, so we weren’t allowed to take our practical exam :-(